Slurry TBM Simulator
Engineering Overview
The Slurry TBM Simulator is an interactive software platform engineered by SMP Engineering to replicate microtunneling boring machine operations in Virtual Reality. Serving as Lead Software Engineer, Yaroslav Anishchenko architected the core system software over a 3-year international development cycle—leading cross-border collaboration with the University of Belgrade and presenting the flagship software model to international industry engineers. The platform integrates real-time physics calculations, low-latency control interfaces, and continuous telemetry streaming for operator certification and geotechnical research.
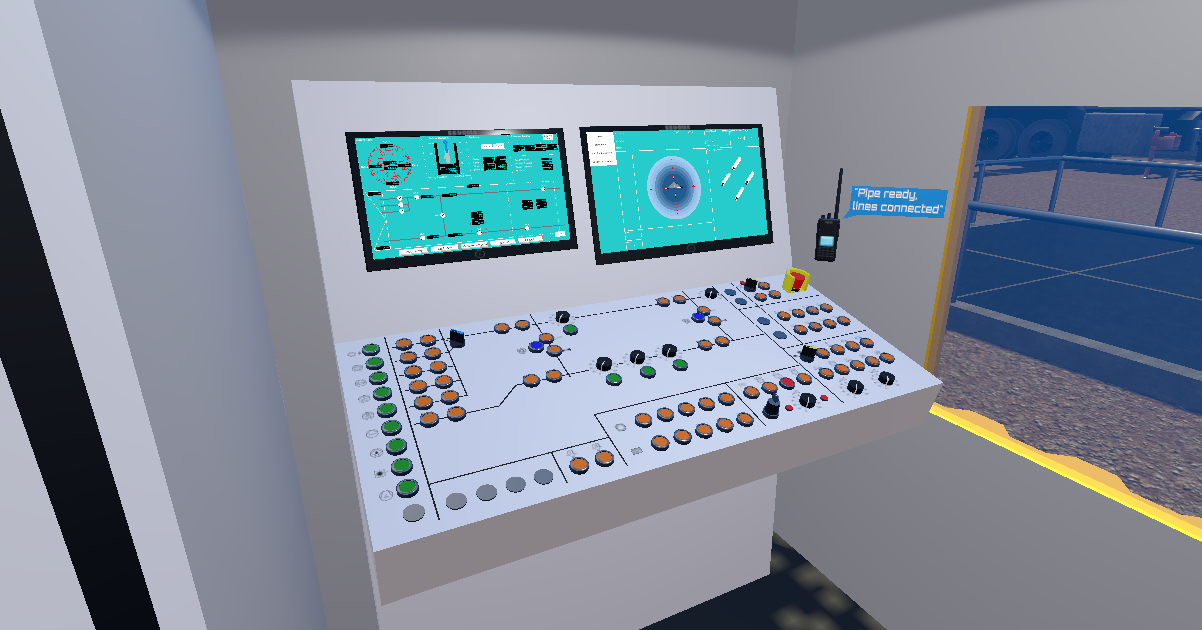
Virtual Reality operator control station recreating the control cabin environment.
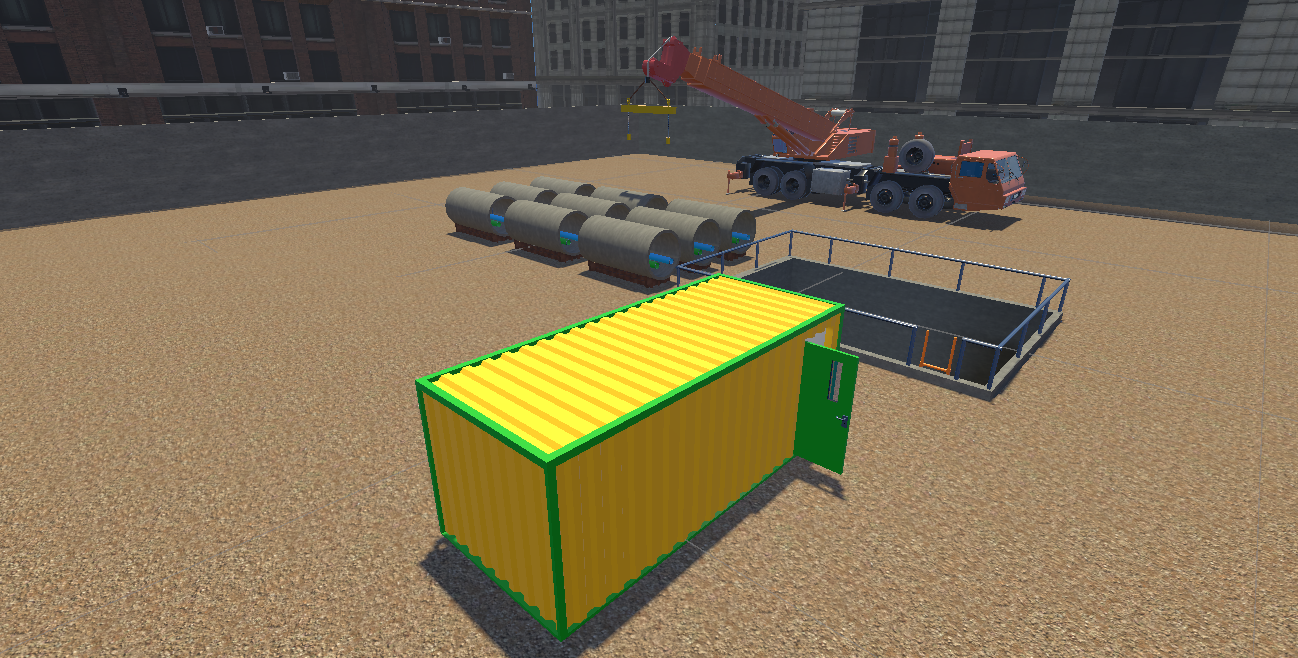
Fully simulated operational pipeline encompassing every phase of microtunneling—from heavy crane pipe loading and hydraulic jacking frame dynamics to internal machine systems, real-time soil excavation, and operator communications.
Interactive 3D Equipment Model
Interactive 3D Mechanical Assembly — Slurry TBM Cutterhead & Cutter Discs (Drag to rotate, scroll to zoom)
System Subsystems & Core Architecture
- Dynamic Forces: Real-time torque, thrust pressure vector distribution, and bentonite slurry displacement calculations.
- Geotechnical Physics: Live mathematical modeling of soil stratum transitions across Clay, Sand, and Hard Rock.
- Execution Performance: Sub-millisecond solver execution optimizing frame rates for Virtual Reality rendering.
- Hardware Interfacing: Custom serial communication bridge translating physical console inputs to virtual controls.
- Ultra-Low Latency: Sub-5ms input-to-render control loop maintaining real-time responsiveness.
- Calibration Protocols: Multi-axis hydraulic lever and precision laser steering calibration routines.
- Data Logging: Continuous sub-second logging of thrust force, cutterhead RPM, and hydraulic pressure.
- Spatial Guidance: Target deviation tracking monitoring X/Y/Z laser alignment and steering cylinder displacement.
- Fault Monitoring: Automated threshold monitoring with visual and auditory error triggers.
- Full-Lifecycle Operations: Dynamic 90-pipe batch sequence management, crane loading kinematics, and walkie-talkie radio audio.
- Session State Persistence: Custom JSON save/restore state engine for instant session restoration and fault recovery.
- Off-Nominal Scenarios: 12 simulated failure modes, including Cutterhead Jams, Hydraulic Drops, and Steering Failures.
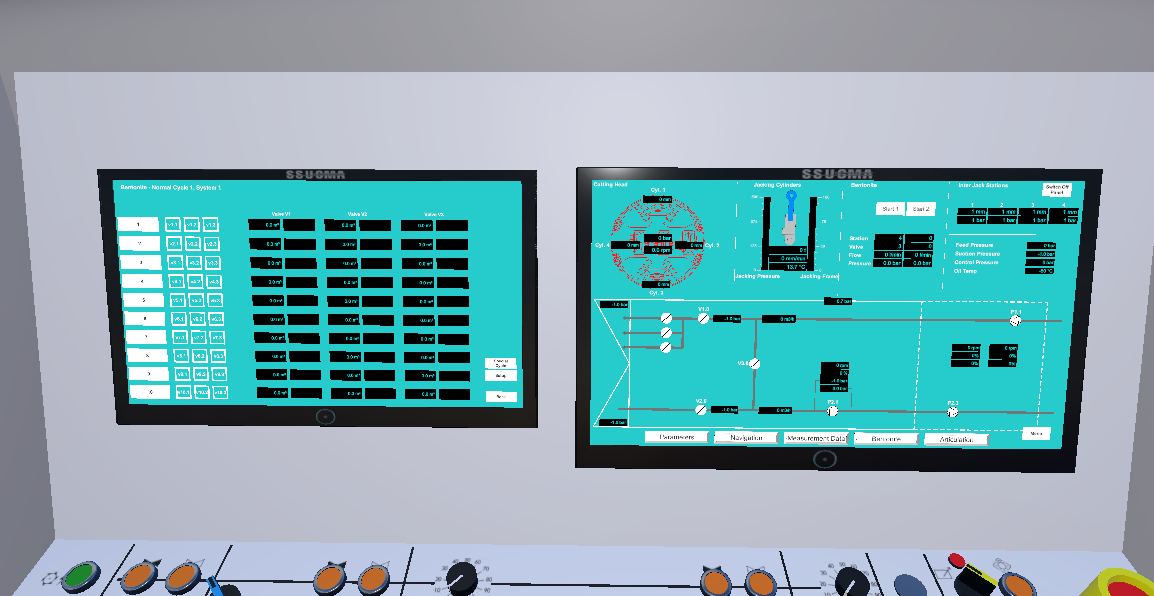
Real-time telemetry user interface rendering cutterhead torque, laser displacement, and steering cylinder hydraulic pressure.
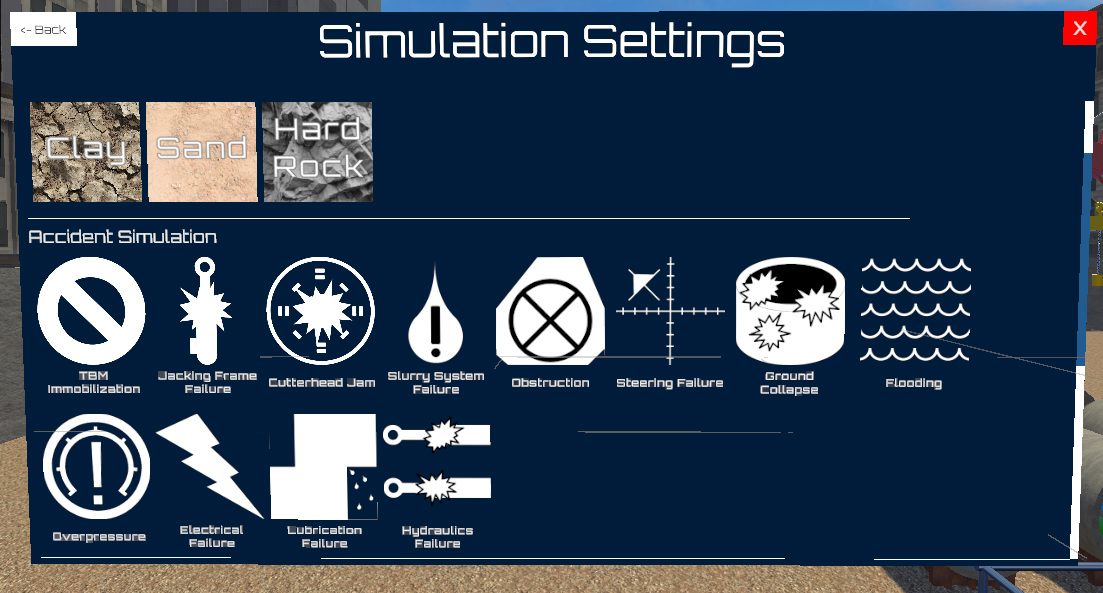
Dynamic environmental and fault simulation engine—allowing real-time switching between Clay, Sand, and Hard Rock strata, alongside 12 off-nominal failure modes including Cutterhead Jam, Steering Failure, Lubrication Failure, and Hydraulics Failure.
Low-Latency Control & Embedded Systems
Direct C++/C# state estimation, sub-5ms serial communication pipelines, and multi-axis hardware controller interfacing.
Real-Time Physics & Kinematic Solvers
Mathematical modeling of cutting mechanics, mechanical friction, fluid displacement, and multi-body dynamics under load.
Spatial Computing & Telemetry Systems
High-performance WebGL/WebAR rendering, real-time sensor data streaming dashboards, and immersive VR operator interfaces.
Conference Presentation & Academic Deployment
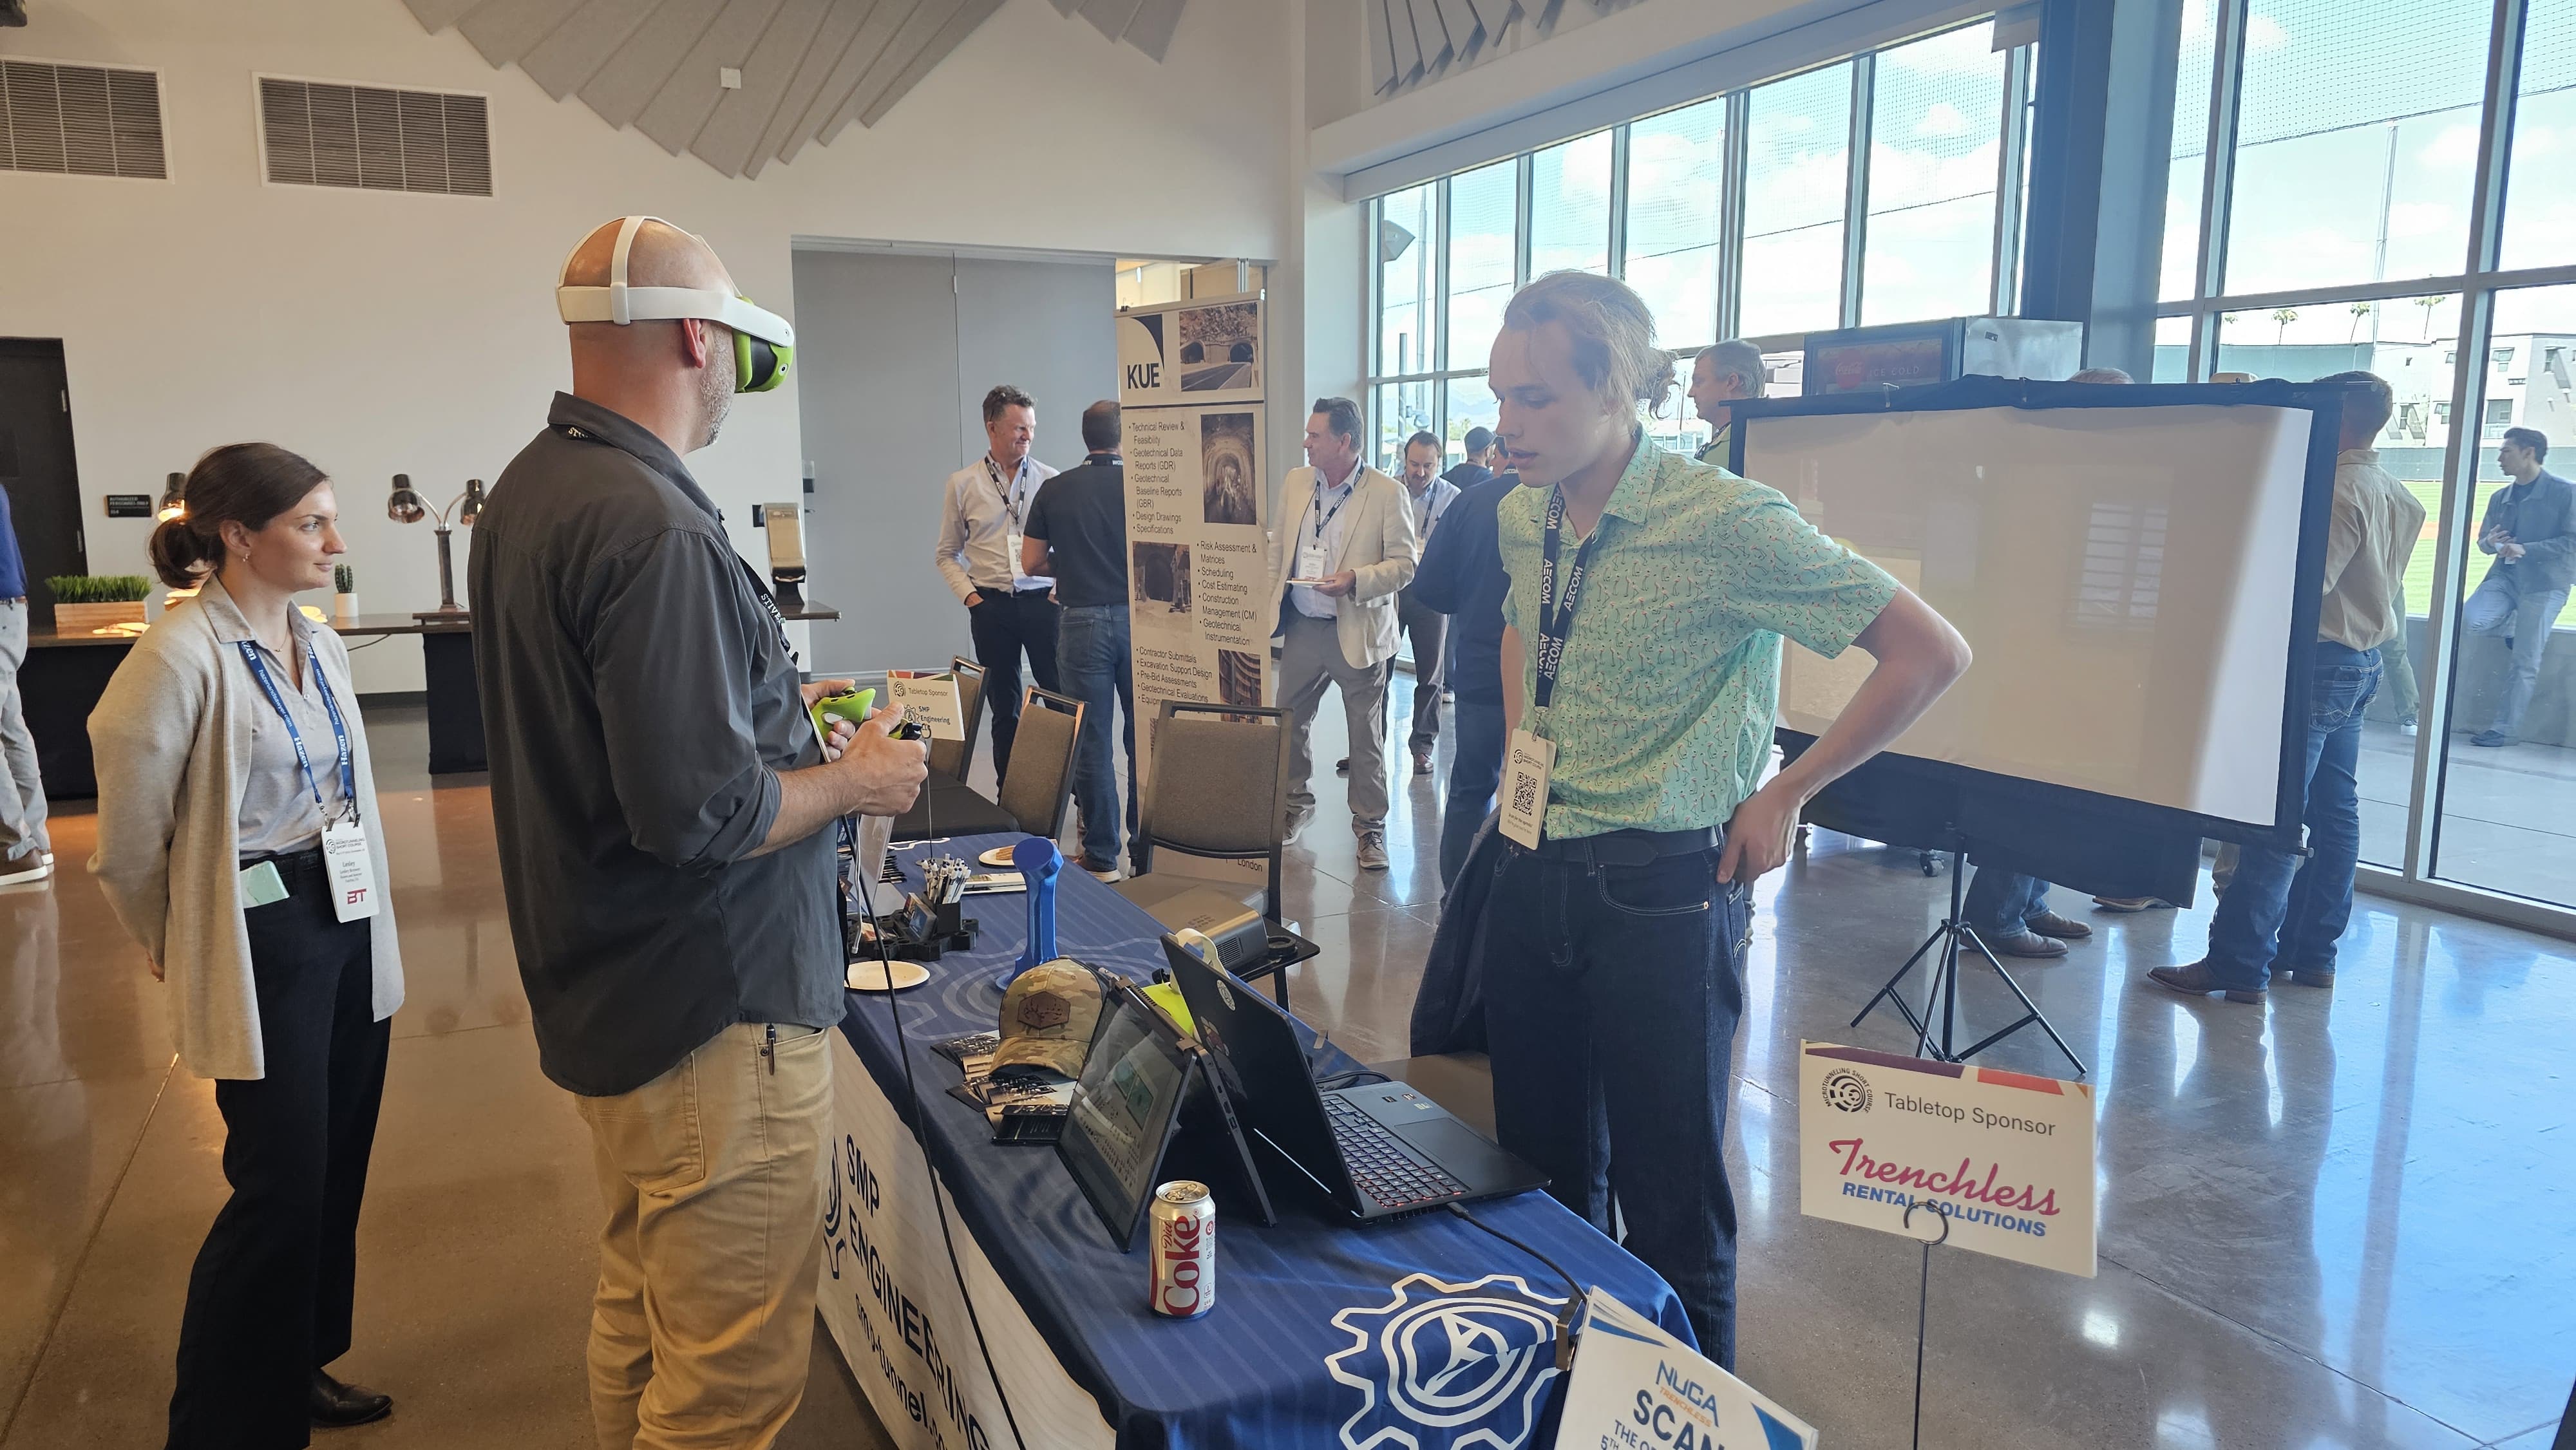
Presentation of the Slurry TBM Simulator architecture to international industry engineers at the Microtunneling Short Course.
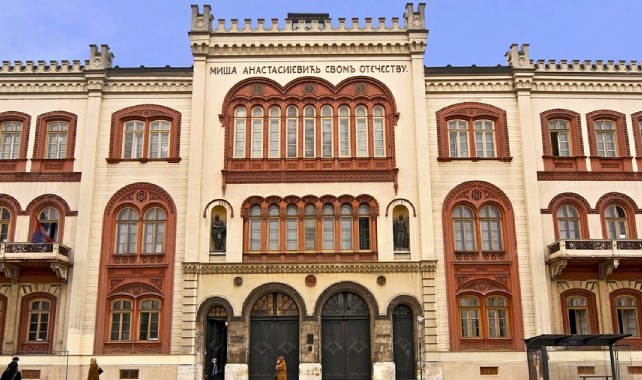
The sofware laid the foundation for state certified university curricula in Belgrade, Serbia and Ankara, Turkey. The largest tunneling and mining companies in the world like Vinci, Bessac and Eurohinka use the simulator to educate their pilots of tunnel boring machines.